When a SCARA robot fits the task
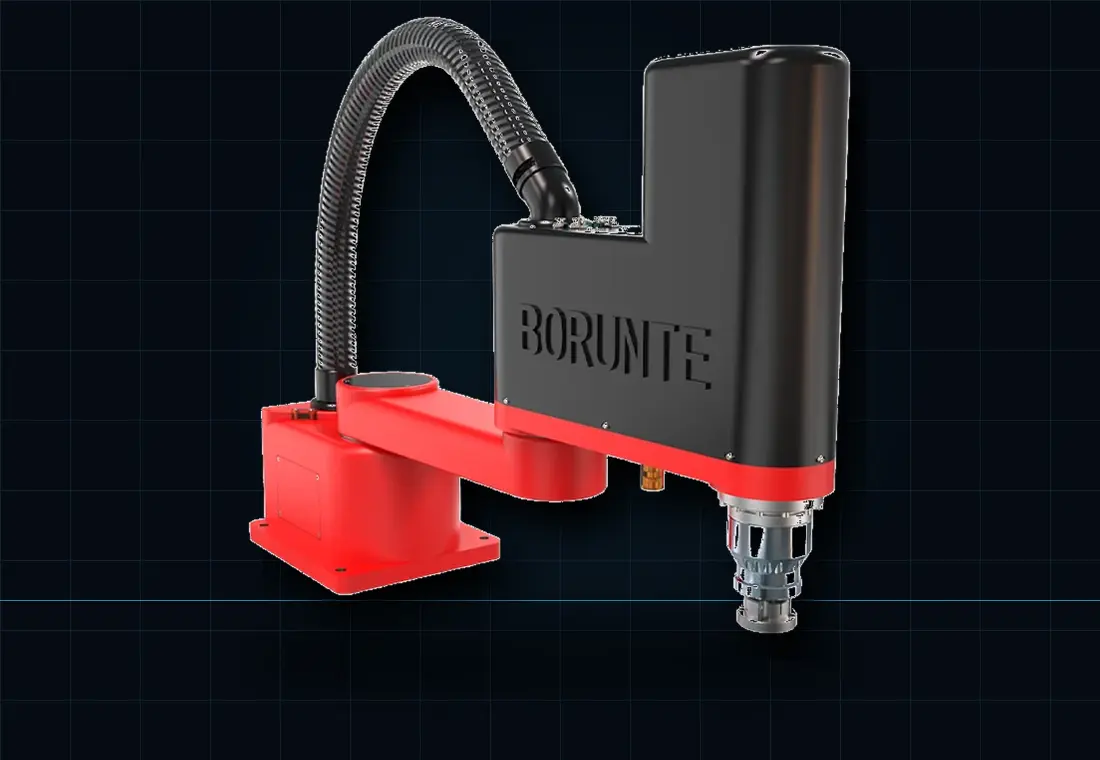
A SCARA robot is designed for rapid movement in the horizontal plane with controlled vertical travel and rotation. That architecture can deliver short cycle times in a smaller work envelope than many articulated robots.
Typical applications include transferring small components between nests, loading trays, placing products into packaging, tending light assembly fixtures and moving parts between test or inspection stations. The best result depends on stable product presentation and a gripper designed for the component rather than the robot alone.
We assess the full moving payload, including gripper, brackets, cables and product. Reach must cover the pick and place locations with appropriate approach clearance; it is not enough for the nominal radius to touch both points. Acceleration, settling time and process dwell are also included when establishing a realistic production cycle.
One complete system, ready for your line
You receive one complete system covering product presentation, end-of-arm tooling, sensing, controls, safeguarding and operator access. The cell is proved against your real production task, not selected from a headline robot specification.