Collaboration is an application decision
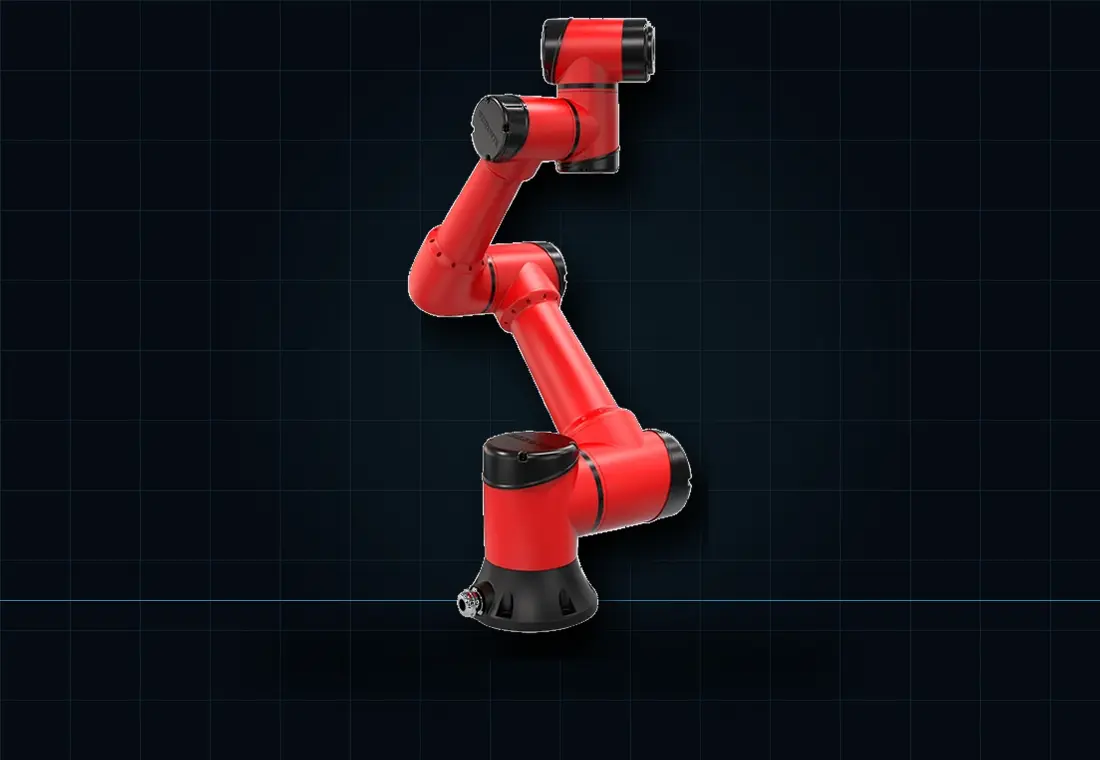
A collaborative robot can support flexible, lower-volume automation, but a cobot arm does not automatically make the complete application safe for unguarded operation.
We assess the product, gripper, speed, force, sharp edges, pinch points and interaction with surrounding equipment. Depending on the risk assessment, the best solution may use power-and-force limitation, monitored stopping, reduced-speed zones or conventional guarding around some or all of the cell.
Typical pick-and-place applications include kitting, light machine loading, sample handling, inspection transfer, end-of-line packing and component presentation. Cobots can also suit operations where production teams value straightforward recipe changes or redeployment, provided the tooling and interfaces have been designed for that flexibility.
One complete system, ready for your line
You receive one complete system covering product presentation, end-of-arm tooling, sensing, controls, safeguarding and operator access. The cell is proved against your real production task, not selected from a headline robot specification.