Throughput comes from the complete flow
A high-speed robot is only productive when the right product reaches the right pick window at the right time. The surrounding handling and control strategy often determine more of the usable output than the arm specification.
We analyse product arrival, spacing, belt speed, queue depth, camera coverage, grip confirmation, place availability and recovery from missed picks. This identifies whether the target requires one robot, several robots sharing a conveyor, buffering, recirculation or a different presentation method.
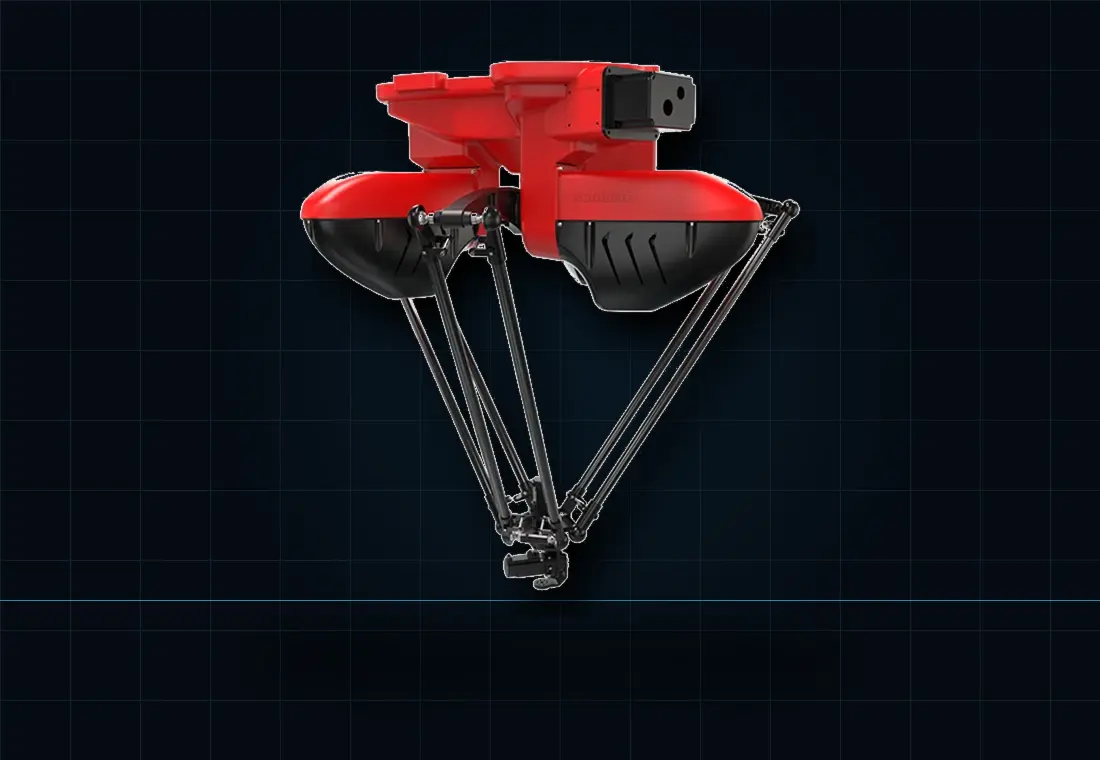
The cell can be engineered for direct transfer, grouping, tray loading, case packing, sorting by type or quality, and orientation before downstream processing. The architecture may use delta robots for lightweight conveyor picking, SCARA robots for compact repeatable transfer or six-axis robots where orientation and reach are more complex.
For products entering trays, cartons or packaging machines, our food and packaging robot guide explains hygiene, gentle gripping and format-change decisions.
The right robot follows your needs
You do not need to choose the robot first. Your product, target rate, movements, access and existing equipment determine whether SCARA, delta, collaborative or six-axis technology will give you the best result, together with the tooling, controls and safeguarding needed for production.